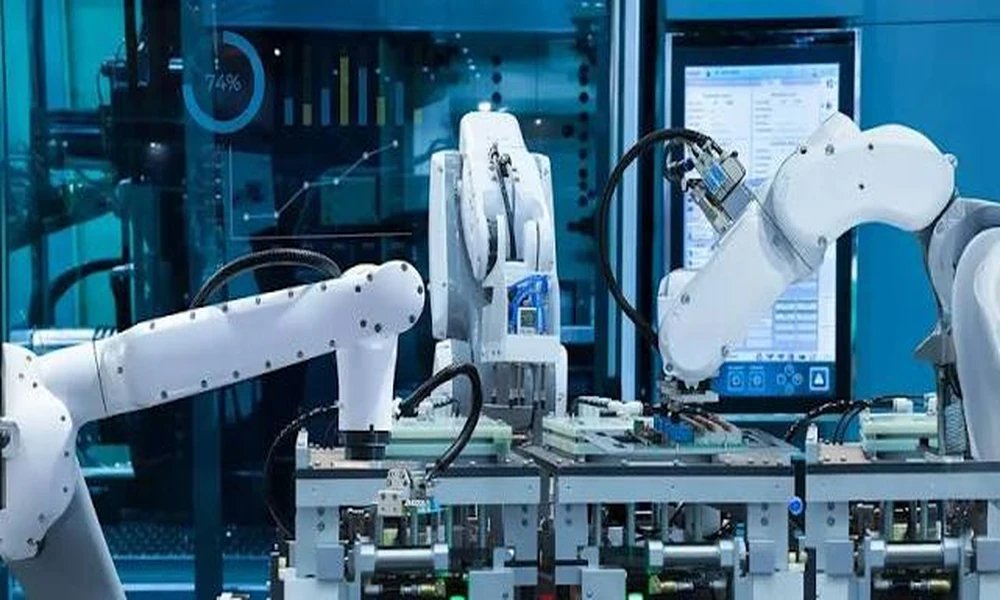
Industrial robot programs have traditionally been built around sequences. Move to a position, close a gripper, wait for a signal, move to another position and continue through the cycle. The approach is transparent and predictable, which is one reason it has worked so well in factories for decades.
The limitation becomes visible when production changes. A new part or machine can require a significant amount of the sequence to be rewritten, even though much of the underlying task is conceptually the same. Reusable robot skills offer another way to organise this logic.
What is a robot skill?
A robot skill can be thought of as a reusable capability rather than a complete production program. “Pick a part,” “load a machine” or “move a workpiece to an outfeed” describes what the system should achieve without necessarily defining every motor command in the instruction itself.
The concept behind Trener AI robot skills is to combine these reusable capabilities with an agentic software layer that helps configure and sequence them for particular manufacturing tasks.
Trener currently positions Acteris around a growing library of production-ready skills, with pick-and-place and machine tending as the first production environments.
The advantage is potential reuse. A skill that has already been developed and validated does not have to be reinvented every time a similar robotic cell is deployed.
Skills are especially relevant to high-mix production
Mass production can justify highly customised automation because the same program may run for years. High-mix factories face a different problem: the application itself changes repeatedly.
Suppose a machine shop runs several families of CNC parts. The gripping points and job parameters may differ, but the robot still performs the same broad operations of picking, loading and unloading.
A skill-based platform can keep those common behaviours consistent while changing the parameters relevant to the next job. This reduces the amount of logic that must be created from scratch during each changeover.
It does not eliminate setup. The robot still needs valid information about parts, tools and machine positions.
Agentic AI changes the operator interaction
Traditional robot programming requires someone to express the desired process in the syntax and structure expected by the controller. An agentic interface attempts to reverse part of that relationship by allowing the user to describe the production intention in a more natural way.
Trener states that Acteris provides a conversational interface through which operators can create production jobs while the underlying system translates the requested task into executable automation.
This could reduce dependence on specialist programming for routine job creation, although complex integration and unusual robotic processes will still require engineering expertise.
The usefulness of such an interface depends heavily on how reliably the system constrains the resulting robot behaviour. In manufacturing, convenient interaction cannot come at the expense of predictable execution.
Reusable skills can also help integrators
System integrators repeatedly solve similar automation problems for different customers. Much of that work is valuable engineering, but some of it involves recreating functions that have already been implemented elsewhere.
A validated skills library can turn parts of this work into reusable software assets. Instead of building every project entirely from one-off scripts, integrators can combine standard capabilities with the configuration unique to the customer.
Trener presents this as one of the reasons Acteris is aimed not only at manufacturers but also at integrators and OEMs. Its partner model focuses on standardised deployment while allowing the integrator to retain application-specific flexibility.
Skills do not make physical robots interchangeable
Reusable software has practical limits. A gripping skill cannot make a robot lift a workpiece heavier than its payload, and a machine-loading routine cannot compensate for insufficient reach.
Tooling, sensors, safety systems and machine interfaces still determine what can be executed physically. Even where two robot brands are supported by the same software platform, their performance and capabilities may differ.
The significance of robot skills is therefore not that hardware stops mattering. It is that industrial automation can begin to reuse more of its software knowledge. If that model proves reliable at scale, manufacturers may spend less time rebuilding familiar robot behaviour and more time adapting proven capabilities to the production problem in front of them.

Clare Louise is a technology writer who focuses on digital trends, emerging tools, and practical tech insights. She simplifies complex innovations into easy-to-understand concepts, helping readers stay informed and confident in a rapidly evolving digital world.